LucidTronix is a new Open-Source Electronics designer. We make
tutorials,
as well as transparent, beautiful, and lucid
devices.
Read more
about us here.
Panoramic Camera
Views:7226Difficulty:
4
Status:
Development

Servo motor, JPEG camera, and Arduino Leonardo combine to make a panoramic camera.
Panoramic Cameras
take beautiful pictures! They are great for shooting landscapes, cityscapes, or apartments for rent when you want to show the whole room. In this tutorial we show how to make a DIY Arduino-based panoramic camera. It can save images to an
SD card
or send them out over the Serial port and USB cable. The camera can be powered by battery or USB. In keeping with our desire to make transparent devices we include a laser-cut plexi glass case for this camera (by the way, it is the same case used in our
time-lapse camera project
.) We are using the
TTL Serial JPEG Camera with NTSC Video
from adafruit, (
they also have a weatherproof version
).

Panoramic Camera and Plexi Glass Case

-
 Panoramic Camera and Plexi Glass CaseThe panoramic camera in its plexi-glass case.
-

 Pan Camera Head OnAs an example of onomatopoetic electronics the panoramic camera is silkscreened with an eye, because this PCB can SEE!
-

 PCB BacksideThe back of the panoramic camera's PCB.
-

 Panoramic Camera PCBThe Front of the panoramic camera (pan cam) PCB. Notice the eye, the SD Card where images can be stored, the LED's and the buttons. This circuit is an example of onomatopoetic electronics , because the silkscreen eye indicates the function of the device: to see! (panoramic pictures).
-

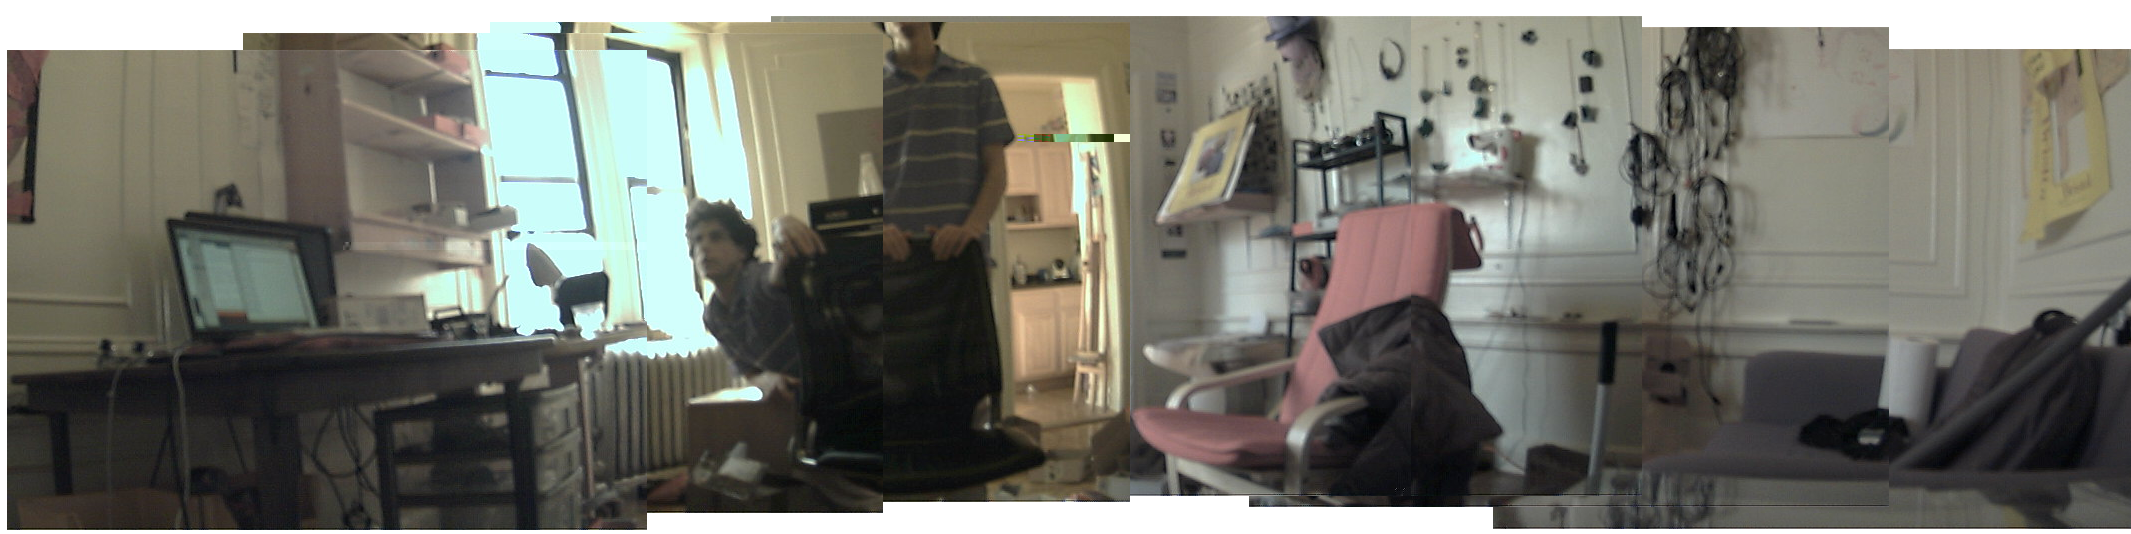
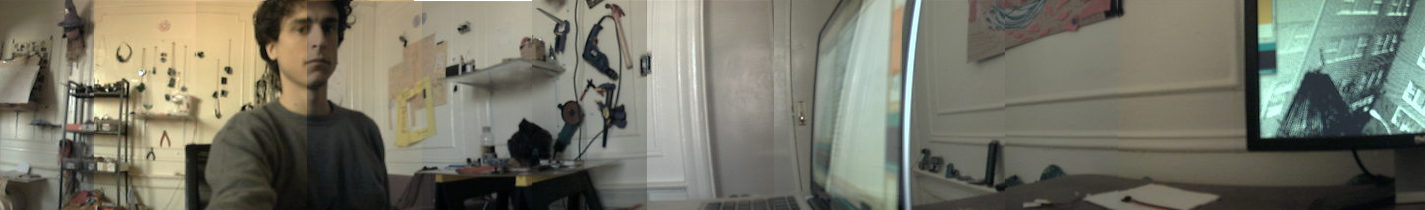
 The First Panoramic PictureThis is the first panoramic picture we took with this Arduino-based panoramic camera. Check out the workshop!
-

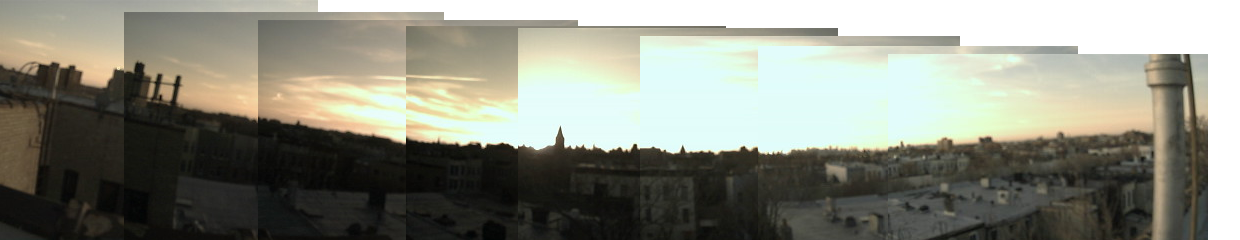
 Panoramic SunsetThe NYC Skyline at sunset. Just 240 pixels of heights because we were debugging... Higher resolution is possible and forthcoming!
-

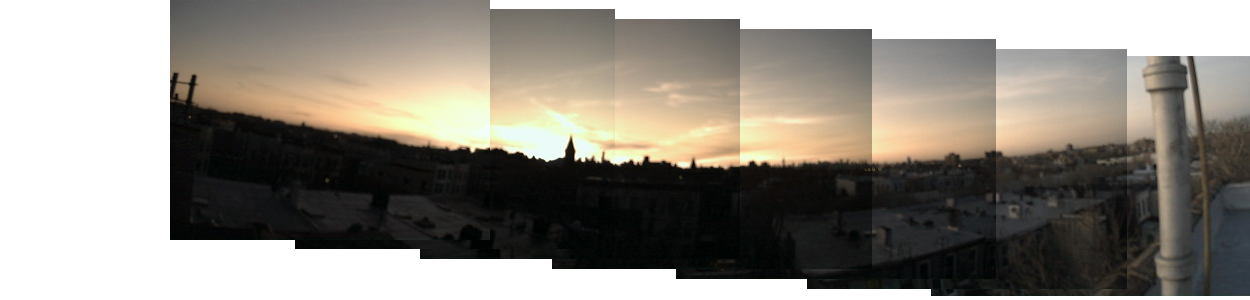
 Sunset Panoramic LaterAs the night lays down over Bushwick and stretches across Brooklyn.
-

 Pan Across The RoomOne fun thing about panoramic pictures is you can be in them many times! Each shot takes at least 5 seconds to save on the SD Card so in that time you can move in the direction the motor rotated the camera and remain in the picture. Notice I'm standing and sitting in this shot!
The panoramic camera in its plexi-glass case.

Video of the Panoramic Camera in Action
The Arduino-based panoramic camera in action!

Links
Panoramic Image Explorer
Panoramic picture texturing a cylinder. Takes a minute to load and requires a webGL enabled browser like
Firefox.
Press the spacebar to load new images and be patient... 3D over IP is still in its infancy :)
Source Code

Arduino Code for Panoramic Camera
Okay now the basic idea of this code is to fix the camera to the motor, then rotate the motor a little bit, take a picture, then wash, rinse and repeat. So we get a bunch of overlapping shots which we can stitch together (by hand or with software). The crux of the algorithm is the function called take_panoramic_picture() [notice the self-documenting code]. The function takes as input the number of pictures to take, and the number of angles to rotate in total. Even at the lowest resolution setting we found that 8 pictures were enough to fully span the 180 degrees that the servo can rotate. take_panoramic_picture loops takes a picture at each rotation increment and saves them to the SD card with names like pan02.jpg, and pan03.jpg. The function goes like this:
void take_panoramic_picture(int pics, int rotate){ // Create an image with the name panxx.jpg char filename[13]; strcpy(filename, "pan00.jpg"); int cur_angle = 0; int angle_inc = rotate/pics; for (int i = 0; i < pics; i++) { pan_servo.write(cur_angle); delay(cur_wait); filename[3] = '0' + i/10; filename[4] = '0' + i%10; take_picture(filename); delay(cur_wait); cur_angle += angle_inc; } }
Lastly, the library list, we use a ton of Arduino libraries in this code so get ready:
Adafruit vc0706 camera library
, the
SoftwareSerial
Library (to talk to the camera), the
SD
Card library (to save the images), the
SPI
protocol library (to talk to the SD Card), and lastly the
Servo
motor library, we need this one to spin the camera around.
Download File
/* Panoramic Camera by LucidTronix * Example pictures, explanation, tutorial at * http://www.lucidtronix.com/tutorials/39 * Uses the vc0706 camera library from adafruit * The camera is fixed to the motor which rotates * and takes a photo every 10 degrees or so. */#include#include #include #include #include Servo pan_servo;SoftwareSerial cameraconnection = SoftwareSerial(8,9);// pass the serial connection to the camera objectVC0706 cam = VC0706(&cameraconnection);#define SD_CS 4 // Set the chip select line to whatever you use (4 doesnt conflict with the library)int pin_pan = 5;int pin_btn = 10;int pan = 0;unsigned int cur_wait = 500;int leds[] = {A0,A1,A2,A3};void setup() { Serial.begin(9600); while (!Serial) { ; // wait for serial port to connect. Needed for Leonardo only } Serial.println("in setup yo."); delay(1400); Serial.println("now gonna try"); Serial.println("VC0706 Camera snapshot test"); // Try to locate the camera if (cam.begin()) { Serial.println("Camera Found:"); } else { Serial.println("No camera found?"); return; } // Print out the camera version information (optional) char *reply = cam.getVersion(); if (reply == 0) { Serial.print("Failed to get version"); } else { Serial.println("-----------------"); Serial.print(reply); Serial.println("-----------------"); cam.setImageSize(VC0706_160x120); // small } // Set the picture size - you can choose one of 640x480, 320x240 or 160x120 // Remember that bigger pictures take longer to transmit! //cam.setImageSize(VC0706_640x480); // biggest //cam.setImageSize(VC0706_320x240); // medium cam.setImageSize(VC0706_640x480); // small // You can read the size back from the camera (optional, but maybe useful?) uint8_t imgsize = cam.getImageSize(); Serial.print("Image size: "); if (imgsize == VC0706_640x480) Serial.println("640x480"); if (imgsize == VC0706_320x240) Serial.println("320x240"); if (imgsize == VC0706_160x120) Serial.println("160x120"); pinMode(pin_btn, OUTPUT); for (int i = 0; i < 4; i++){ pinMode(leds[i], OUTPUT); } Serial.println("Trying SD Card.."); pinMode(SD_CS, OUTPUT); digitalWrite(SD_CS, HIGH); while (!SD.begin(SD_CS)) { Serial.println(" no SD card :("); Serial.println("will try again in 10 seconds.."); delay(10000); } Serial.println("SD Card Ready!"); for (int i = 0; i < 4; i++){ digitalWrite(leds[i], HIGH); } delay(500); for (int i = 0; i < 4; i++){ digitalWrite(leds[i], LOW); } delay(500); pan_servo.attach(pin_pan); Serial.print("Ready to take image! Press the Button!");}void loop(){ if (digitalRead(pin_btn) == HIGH) { take_panoramic_picture(8,170); Serial.print("Pan Image Taken"); }}void take_panoramic_picture(int pics, int rotate){ // Create an image with the name panxx.jpg char filename[13]; strcpy(filename, "pan00.jpg"); int cur_angle = 0; int angle_inc = rotate/pics; for (int i = 0; i < pics; i++) { pan_servo.write(cur_angle); delay(cur_wait); filename[3] = '0' + i/10; filename[4] = '0' + i%10; take_picture(filename); delay(cur_wait); cur_angle += angle_inc; } }void take_picture(char * filename){ Serial.println("Snap in 1 secs..."); delay(1000); if (! cam.takePicture()) Serial.println("Failed to snap!"); else Serial.println("Picture taken!"); // Create an image with the name filename // Open the file for writing // delete it if it exists delay(200); SD.remove(filename) ; delay(100); File imgFile = SD.open(filename, FILE_WRITE); // Get the size of the image (frame) taken delay(100); uint16_t jpglen = cam.frameLength(); Serial.print(jpglen, DEC); Serial.println(" byte image"); pan_servo.detach(); int32_t time = millis(); // Read all the data up to # bytes! while (jpglen != 0) { // read 64 bytes at a time; uint8_t *buffer; uint8_t bytesToRead = min(32, jpglen); // change 32 to 64 for a speedup but may not work with all setups! buffer = cam.readPicture(bytesToRead); imgFile.write(buffer, bytesToRead); jpglen -= bytesToRead; } imgFile.close(); delay(50); cam.reset(); pan_servo.attach(pin_pan);}void blink_leds(int wait){ for (int i = 0; i < 4; i++){ digitalWrite(leds[i], HIGH); delay(wait); } for (int i = 0; i < 4; i++){ digitalWrite(leds[i], LOW); delay(wait); }}

Parts
| Title | Description | # | Cost | Link | Picture |
| TTL Serial JPEG Camera with NTSC Video | Camera from adafruit | 1 | $39.95 | Link |

|
| Stepper Motor | BiPolar Stepper motor from sparkfun. | 2 | $14.95 | Link |

|
| PCB for SD Card and Camera | PCB supports camera and SD card atmge32u4 and USB. | 1 | $7.0 | Link |

|
| ATMEGA32U4-MU | Integrated Circuits MCU AVR 32K FLASH 16MHZ 44-QFNValue:2.7 V ~ 5.5 V 16MHz | 1 | $6.04 | Link |

|
| SD Card (micro 4GB) | MicroSD Card 4GB with full-size SD card adapterValue:4GB | 1 | $5.35 | Link |

|
| microSD Card Connector | Secure Digital - microSD™ Push In, Push OutValue: microSD | 1 | $3.44 | Link |

|
| Battery Holder | Holds 3 AAA Batteries. Has on/off switch.Value:4.6V | 1 | $1.95 | Link |

|
| USB connector | USB Mini type BValue:female | 1 | $0.68 | Link |

|
| Crystal | CRYSTAL 16.00000 MHZ 20PF SMDValue:16MHz | 1 | $0.53 | Link |

|
| Button | Tactile switch SMD SPST 0.05A 12VValue:SPST | 3 | $0.2 | Link |

|
| Resistor Array | RES ARRAY 300 OHM 4 RES 1206Value:300 | 1 | $0.02 | Link |

|


Tutorials

Spherical Camera
Arduino-powered spherical camera with 2 Servo Motors and an SD Card....

This PCB controls a camera and an SD card so you can make automatic time lapse videos. ...

Mixing pixels from two face images together....

Handheld gaming machine, based on the Arduino Leonardo, equipped with joystick, SD card and more....

Our take on the classic bouncing ball, paddle game....

Wall-ter is a wall following robot....

Print bitmaps, cellular automata, drawings and text.....

Light sensors guids this robot towards the light....

Comments: